Decision definition
Specify the action, error costs, operating envelope, review path and threshold for useful performance.
Evidence: Decision specification and error-cost matrix.
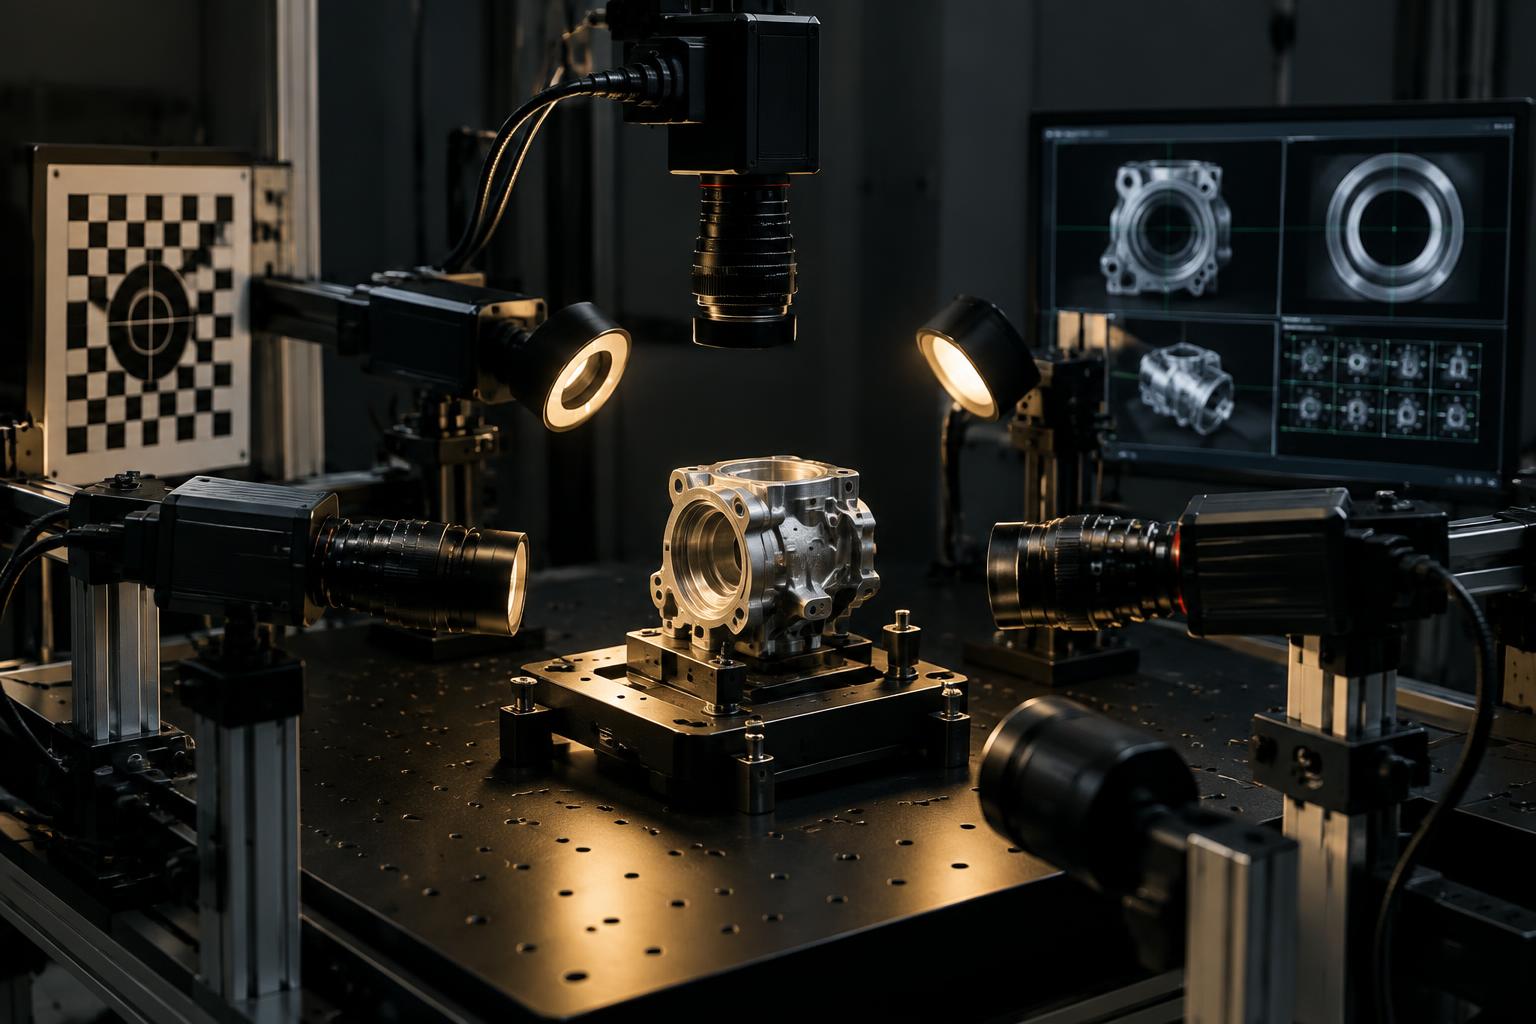
Machine perception
Engineer the complete sensing decision—not just a model—from optics and data provenance through edge performance, human review and drift detection.
The operating problem
Lighting changes. Objects arrive at unfamiliar angles. Sensors age, labels hide ambiguity and a confident model can still be wrong in the case that matters. We treat perception as an operating system with measurable boundaries, not an isolated training exercise.
A visual inspection or detection task is still dependent on inconsistent manual judgment.
A prototype works in controlled data but has not been characterized in the field.
False positives and false negatives carry different operational consequences.
Latency, compute, optics or connectivity constrain where inference can run.
Engineering position
Sensor geometry, lighting, sampling and label policy are engineering decisions that determine what the model can know.
Evaluation is sliced by operating condition and consequence, exposing weak regions hidden by a single aggregate score.
Uncertainty, review queues and override paths preserve accountable human decisions where automation should not act alone.
Delivery sequence
Specify the action, error costs, operating envelope, review path and threshold for useful performance.
Evidence: Decision specification and error-cost matrix.
Assess optics, illumination, placement, synchronization and representative capture conditions.
Evidence: Capture protocol, calibration plan and coverage report.
Create traceable datasets, baselines and model iterations while testing leakage, imbalance and label uncertainty.
Evidence: Dataset lineage, experiment register and evaluation slices.
Measure latency, throughput, thermal limits, connectivity, fallback behavior and integration with the receiving workflow.
Evidence: Deployment profile and end-to-end acceptance results.
Instrument drift, uncertain cases, overrides and retraining triggers without silently changing production behavior.
Evidence: Monitoring thresholds, review queue and controlled update procedure.
Handover
Operating envelope, error taxonomy, decision thresholds and the role of human review.
Versioned samples, labels, provenance, exclusions and documented coverage gaps.
Model and sensing pipeline tested by condition, consequence and target deployment hardware.
Signals for drift, uncertainty, overrides and controlled escalation after release.
Decision gate
Deploy only when performance is demonstrated across the declared operating envelope, consequential errors have a safe response and the system can reveal when reality has moved beyond its evidence.
Discuss this workOne-pager
A single printable page covering what we do here, how engagements run and what to send us to start. Useful for forwarding internally.
PDF · 257 KB